Study
Participants completed fast, repetitive kitchen tasks in a lab simulation. The evaluation combined task analysis, reach-frequency mapping, interface inspection, and observation of user error.
Human–Robot Interaction / Miso Robotics / usability study
An in-lab simulation of a busy lunch hour uncovered reach, interface, cleaning, and food-safety risks around an automated fry station.
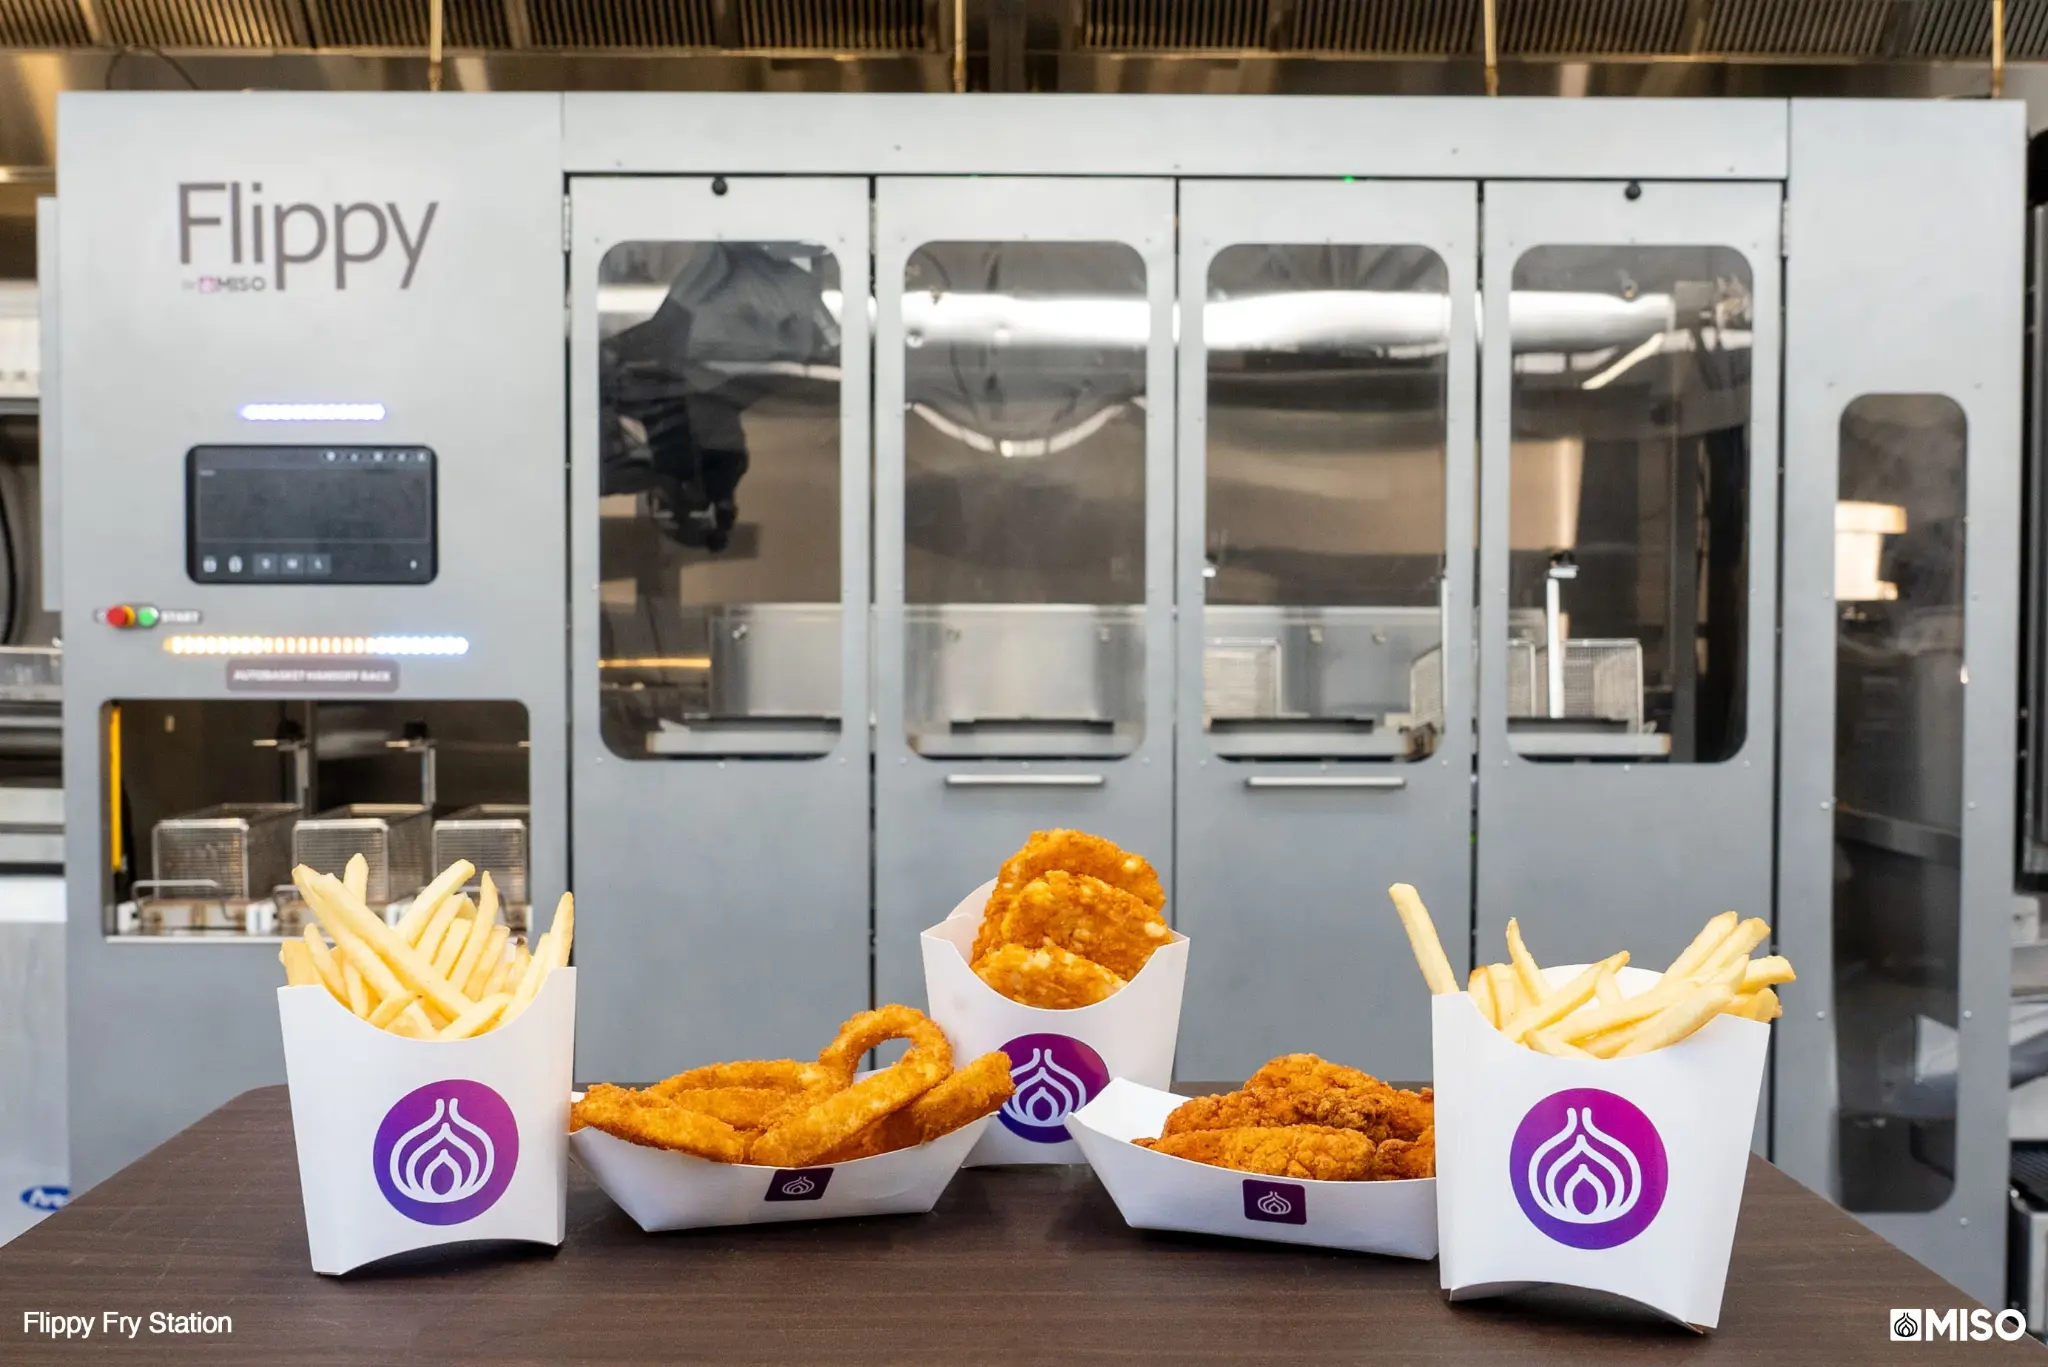
Participants completed fast, repetitive kitchen tasks in a lab simulation. The evaluation combined task analysis, reach-frequency mapping, interface inspection, and observation of user error.
Frequent actions were not always within comfortable reach, the screen could flex under force, and inconsistent cleaning language created avoidable uncertainty. Some hard-to-reach areas were cleaned weekly rather than daily.
Strengthen and firmly mount the display, place frequent actions inside comfortable reach, use consistent cleaning states, and add computer vision plus weight verification to reduce food-identification errors.