What Robots Need From Clothes
A framework for designing functional clothing for human–robot interaction.
Researcher · Artist · Maker
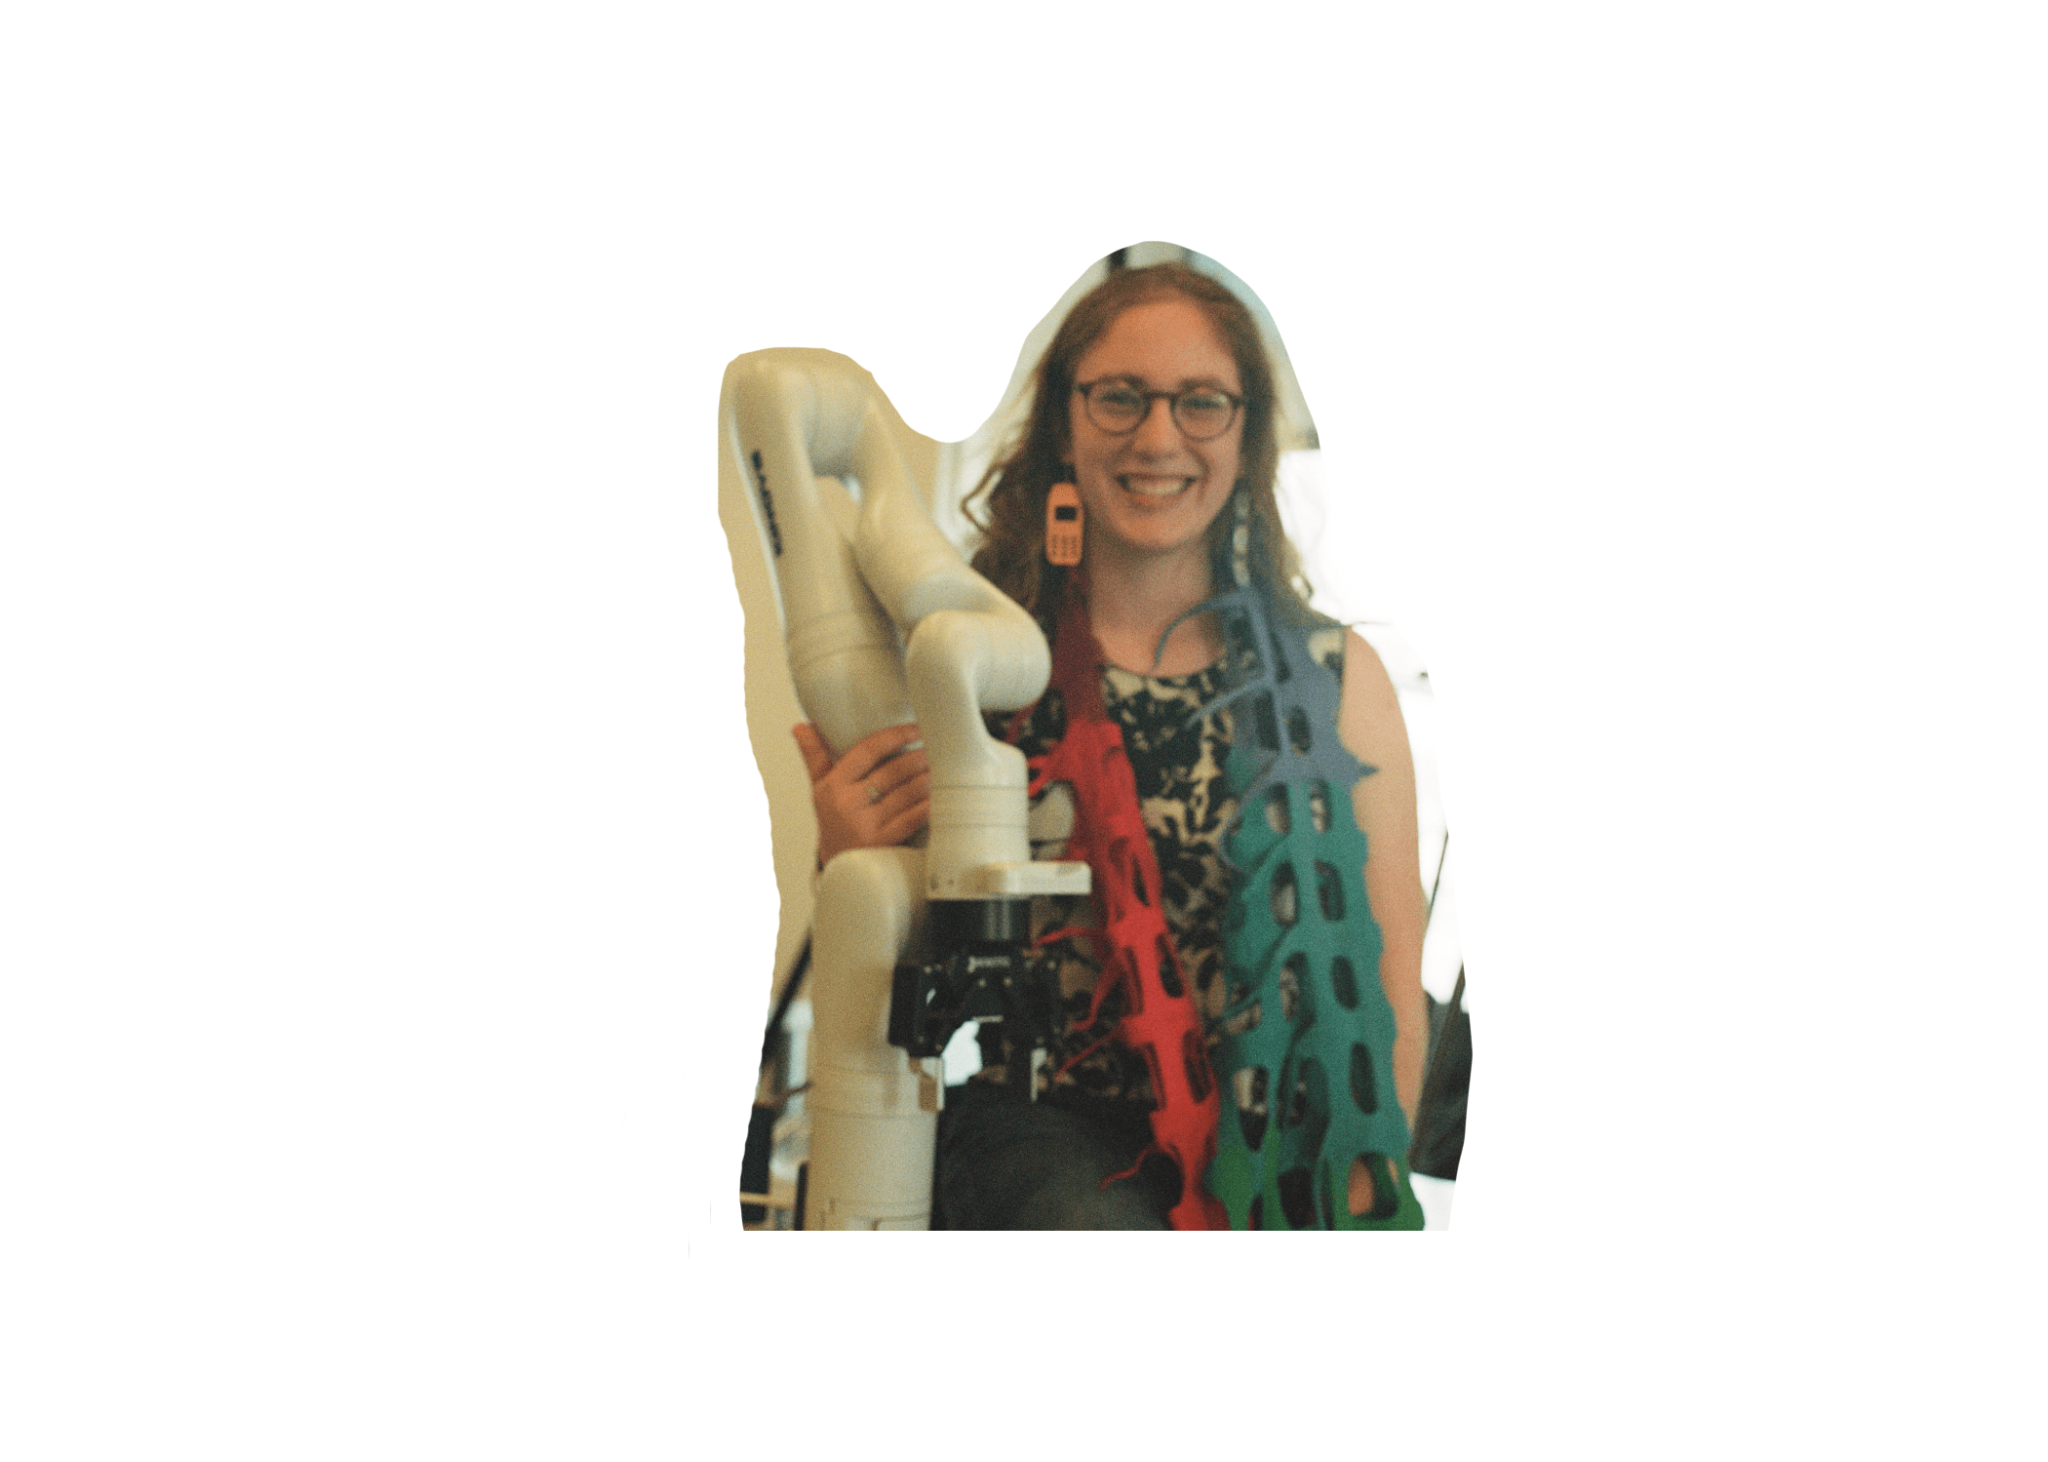
About Natalie
I received a PhD in Information Science from Cornell Tech, where I focused on human–robot interaction. My research and art meet in questions about how technology communicates, belongs, and adapts.
My work moves between human–robot interaction, emerging technology, art, and the everyday materials that make machines legible to people.
Selected work
Research spanning human interaction with robotics, autonomous vehicles, and AI.
01 / Human–Robot Interaction
Studying how farm workers interact with automation to design robot behavior that fits real agricultural practices.
↗︎
02 / Human–AI Interaction
To understand how formatting of LLM output impacts people, the Node-tree interface helped preserve context and support brainstorming tasks.
↗︎
03 / Human–Robot Interaction
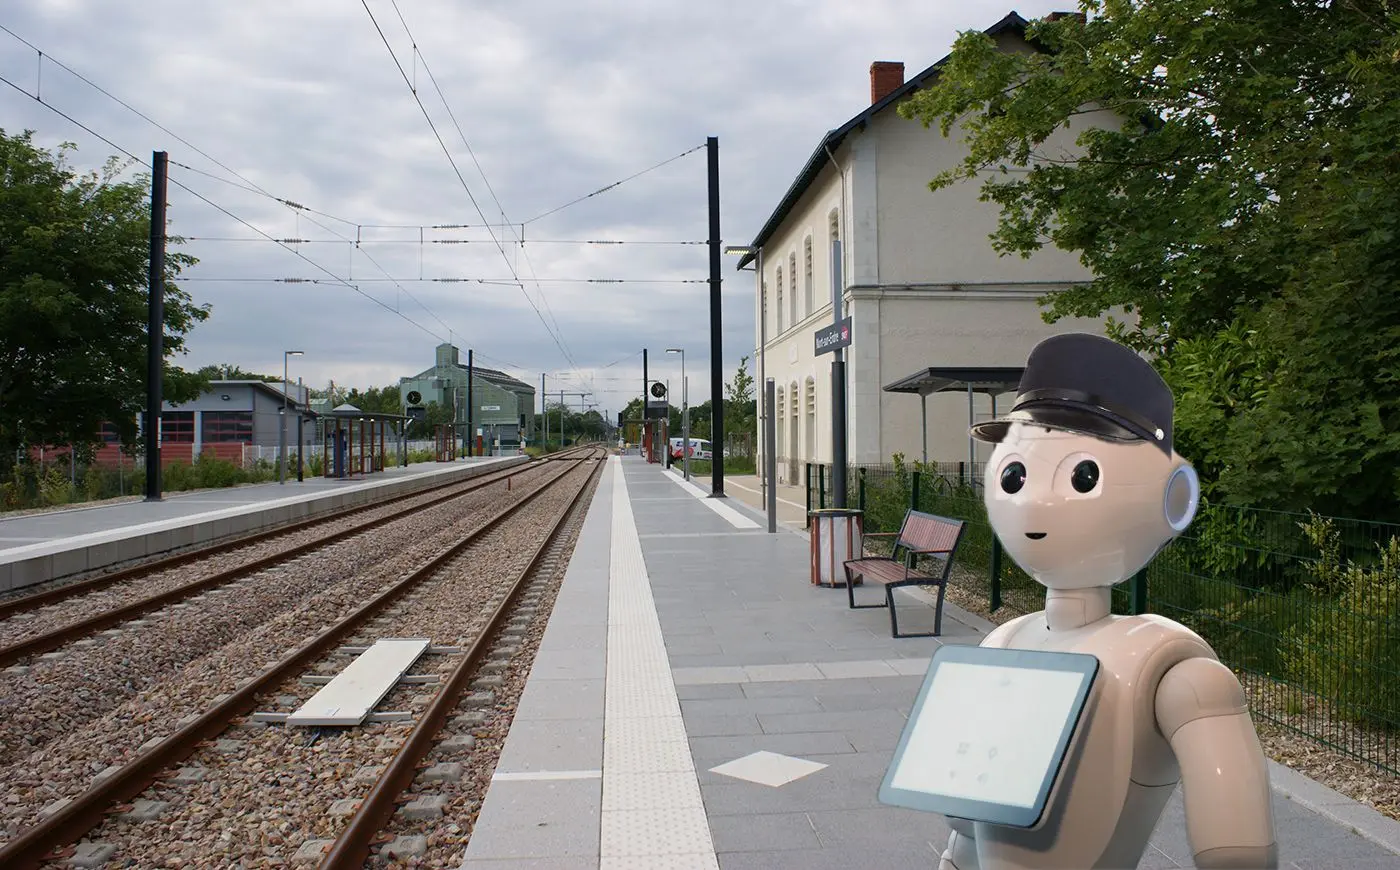
Clothing can help robots signal social roles, adapt to new environments, and work safely in dirty or dangerous settings.
↗︎04 / Autonomous Systems
Researching how culture and context shape the way people understand and interact with autonomous vehicles.
↗︎
Art practice
From drawing people and film photography to ceramics, watercolors, digital art, and a robot fashion show, my creative practice grows through personal connection and experimentation.
Selected publications
A framework for designing functional clothing for human–robot interaction.
A dataset for detecting and understanding failures in human–robot interaction.
Designing future farm-management information systems around real practices.